If you’ve ever walked through a plastic manufacturing floor, watched an injection molding machine spit out hundreds of identical parts an hour, and thought, “There’s got to be a better way to handle those parts than having a worker stand there all shift,” you’re not alone. I’ve been in this industry for 12 years, first as a factory floor supervisor, and now as an injection molding robot supplier, and I’ve seen firsthand how a poorly installed robot can turn a $50,000 piece of machinery into a $10,000 paperweight. It’s not rocket science, but it does require attention to detail, respect for the machine’s specs, and a little common sense. Today, I’m breaking down exactly how we do it at our shop—no fluff, no guesswork, just the steps that get our clients’ robots up and running reliably, without the headaches that come with rushed installations. Injection Molding Robot
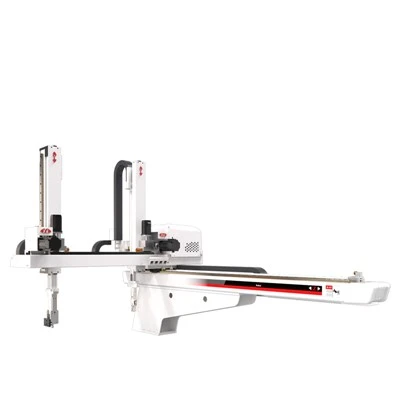
First, before you even touch a single bolt or plug a cord in, there’s a step most people skip that comes back to haunt them later: site assessment and prep. I can’t tell you how many times I’ve showed up to a job, only to find the injection molding machine is crammed so tight against a wall there’s no room for the robot’s base, or the floor has a 2-degree slope that will make the arm wobble every time it moves. A proper site check needs to happen 3 to 5 days before the robot is scheduled to arrive, and it covers three key areas. First, floor stability. Injection molding robots are heavy—our smallest tabletop models weigh 1,200 pounds, and the large 6-axis robots that handle big parts can tip the scales at 8,000 pounds minimum. The floor has to be rated for that weight, no exceptions. We always carry a floor leveler in our tool bag, and we spend 15 minutes measuring the slope in three different spots around where the robot will sit. If the floor is off by more than a quarter-inch over four feet, we tell the client to either grind it down or add a cement pad. Wobbling isn’t just annoying—it’ll cause the robot to mispick parts, knock over molds, or even damage itself over time.
Next, power and utility access. Most small to mid-sized injection molding robots run on 480V three-phase power, and they need a dedicated circuit—no sharing with the molding machine, no extension cords. I once worked with a shop that tried to power their new robot off the same circuit as their 500-ton molding machine, and every time the machine cycled, the robot would glitching and throw an error code. We had to rewire the whole thing, which cost them twice as much as a separate circuit would have. Also, make sure there’s compressed air and Ethernet ready. The end of arm tooling (EOAT)—the grippers that pick up parts—needs consistent air pressure, usually around 80 PSI, and the robot needs to talk to the molding machine to sync cycles. No Ethernet means no communication, which means the robot will either pick parts too early or too late, leading to scrap. If the client doesn’t have an Ethernet port right by the machine, we run a CAT6 cable ourselves during the installation—better to do it right than call them back later for a fix.
Finally, layout clearances. The robot’s arm has to have enough space to extend, retract, and rotate without hitting anything—molds, conveyor belts, other machines, even overhead pipes. We use the robot’s work envelope specs from the manual, and we mark out the exact space with spray paint on the floor before we uncrating the unit. A common mistake is placing the robot too close to the ejection side of the molding machine. The ejection side is where the parts come out hot, and if the robot is in the way, it’s just a matter of time before a hot part damages the EOAT. Our rule of thumb is to leave at least 18 inches of clearance on the ejection side, plus another 12 inches for any conveyors or part chutes.
Once the site is ready, it’s time to uncrating and position the robot. This step sounds simple, but it’s where a lot of installers cut corners. The robot comes strapped to a wooden pallet, and we never try to lift it with a forklift by the pallet’s edge—those pallets are built to hold the robot, not lift it. We use a forklift with spreader bars, or a crane for the larger models, and we always keep the robot level while moving it. Once it’s in place, we lower it slow, and use those floor leveler readings to adjust the mounting feet. Most robots have adjustable feet that can raise or lower by a couple of inches, and we spend time tweaking each foot until the robot is perfectly level. I always double-check the level in two directions—front to back and side to side—because even a small tilt can throw off the arm’s path. We also make sure the mounting bolts are torqued to the exact specification in the manual, usually around 50 foot-pounds for small robots, up to 150 for large ones. A loose bolt will work its way loose over time, and before you know it, the robot is making strange noises or shifting position.
Next, we install the end of arm tooling (EOAT) and any auxiliary equipment like part inspection sensors or conveyors. The EOAT is custom for each job—grippers for flat plastic parts, vacuum cups for large curved parts, even specialized tools for handling delicate medical components. This is where we work directly with the client’s team, because they know the parts better than anyone. We test the gripper’s grip first on a scrap part from their molding machine, not the good production parts, to make sure it doesn’t squeeze too hard and warp the part, or too soft and drop it. We also add any safety features here, like light curtains or safety fences around the robot’s work area. OSHA has very specific rules for industrial robot safety, and we never skip that step. A few years back, we had a client who forgot to install a light curtain, and a worker stepped into the robot’s path to grab a part—luckily, the robot stopped in time, but it cost them a $12,000 fine from OSHA, plus downtime. Now, we always walk the client through every safety feature, and we make sure they sign off on it before we move on.
Once all the physical parts are in place, it’s time for electrical and software setup. This is the most technical part, and it’s not something we let just any technician handle. The first step is connecting the power cable to the dedicated circuit, and grounding the robot properly. Bad grounding will cause electrical interference, which can mess up the robot’s sensors and cause random errors. We use a digital multimeter to test the voltage at the terminal block, and we make sure it’s within 5% of the rated voltage—anything lower, and the robot won’t have enough power to move the arm fast enough, leading to slower cycle times.
Then, we connect the communication cables between the robot and the molding machine. Most modern molding robots use Modbus or Ethernet/IP to sync with the machine, which tells the robot when the molding cycle is done, when the mold is open, and when it’s safe to pick the part. We set up the communication protocol step by step, and we do a test cycle manually first, before we let the robot run automatic. We watch as the mold opens, wait for the cooling time to be almost done, then trigger the robot to move—making sure it doesn’t hit the mold, and that the gripper picks up the part cleanly.
After that, we program the robot’s path. This is where experience matters a lot. We don’t just plug in numbers; we watch how the arm moves, make adjustments to the speed and acceleration to make sure it’s not jerky, and optimize the path to cut down on cycle time. For example, if the robot has to move from the mold to the conveyor, we might adjust the path to go around a pillar instead of straight, which saves a half-second per cycle. That half-second adds up to thousands of parts a year. We also set up safety limits, so the robot can’t move faster than a certain speed near the operator’s area, or stop immediately if it hits an obstruction.
Now, the part everyone waits for: testing and commissioning. This is when we run the robot through 50 to 100 full production cycles, watching every step. We check for part accuracy—making sure the part is placed correctly on the conveyor, no scratches or dents from the gripper. We check cycle time, compare it to the client’s target, and make small adjustments if needed. We also test the robot in different conditions—like if there’s a small variation in part size from the molding machine, does the robot still pick it up reliably? We have a checklist we go through, covering everything from EOAT grip strength to alarm codes, and we don’t leave until every item is checked off. We also train the client’s maintenance team and operators how to run the robot, basic troubleshooting, and how to do routine checks like tightening bolts or cleaning the air filter for the grippers. I always tell them, the robot only works as well as the people running it. We give them our contact info, and we follow up a week later to make sure everything is still running smoothly.
I know installing a robot can sound overwhelming, but the truth is, a good installation will pay for itself in less than a year, with reduced labor, fewer scrap parts, and faster cycle times. If you’re thinking about adding an injection molding robot to your floor, don’t trust just any installer. Work with a supplier that has experience, that takes the time to do the site prep right, that doesn’t cut corners on safety or testing. If you’re ready to talk about what kind of robot would work best for your parts, or you have questions about the installation process, reach out to our team—we’re here to help you make your production line run smoother.
Industrial Robot References
- Robotic Industries Association. (2022). Industrial Robot Installation Best Practices. RIA Report R15.06.
- Occupational Safety and Health Administration. (2021). Safety Standards for Industrial Robots and Robot Systems. OSHA 3557-11R.
- Society of Plastics Engineers. (2020). Injection Molding Automation Guide: Robotic Integration and Installation. SPE Publication.
- International Organization for Standardization. (2019). Robots for Industrial Applications – Safety Requirements – Part 1: Robots. ISO 10218-1:2019.
- Miller, T. (2021). "Common Pitfalls in Injection Molding Robot Installation and How to Avoid Them." Journal of Manufacturing Automation, 45(3), 112-118.
Robotic Technology (GD) Co., Ltd.
Robotic Technology (GD) Co., Ltd. is one of the most experienced injection molding robot manufacturers and suppliers in China, also supports custom service and one year warranty. Please feel free to wholesale CE approved injection molding robot for sale here from our factory. Contact us for quotation.
Address: Room 102, No. 30,Hengfeng 2nd Road,Daguo, Changping Town, Dongguan City,Guangdong,China
E-mail: admin@iroboticplus.com
WebSite: https://www.rb-tic.com/
